Zhuoyuan Jacob Wang

Hi, I’m a postdoctoral researcher in Computing and Mathematical Sciences at California Institute of Technology, working with Prof. Anima Anandkumar. I received my Ph.D. in Electrical and Computer Engineering from Carnegie Mellon University, advised by Prof. Yorie Nakahira. I earned my bachelor’s degree from Tsinghua University, advised by Prof. Gao Huang and Prof. Yilin Mo.
My research interests lie at the intersection of control theory and scientific machine learning, with a focus on safety-critical control, physics-informed learning, stochastic systems and robotics.
Contact: jacobw [at] caltech.edu
Follow: Google Scholar | LinkedIn | jacobwang925
news
| Aug 23, 2026 | Our paper “OpInf-LLM: Parametric PDE Solving with LLMs via Operator Inference” was accepted to Transactions on Machine Learning Research (TMLR) with Featured Certification! |
|---|---|
| Apr 23, 2026 | PI-BSNet and OpInf-LLM will be presented as posters at the ICLR 2026 AI + PDE Workshop! |
| Feb 20, 2026 | Our paper “Physics-Informed Deep B-Spline Networks” was accepted to Transactions on Machine Learning Research (TMLR)! |
| Jan 22, 2026 | Our paper “Online Adaptive Probabilistic Safety Certificate with Language Guidance” was accepted to L4DC 2026! |
| Dec 23, 2025 | Our paper “Myopically Verifiable Probabilistic Certificates for Safe Control and Learning” was accepted to IEEE Transactions on Automatic Control (TAC)! |
selected publications
- L-CSS
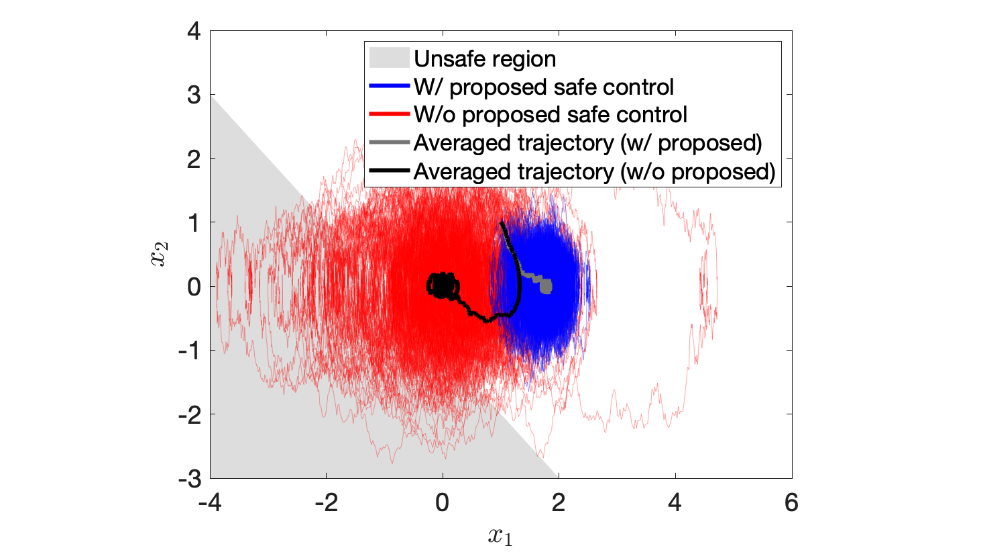 Scalable Long-Term Safety Certificate for Large-Scale SystemsIEEE Control Systems Letters, 2023
- TPAMI
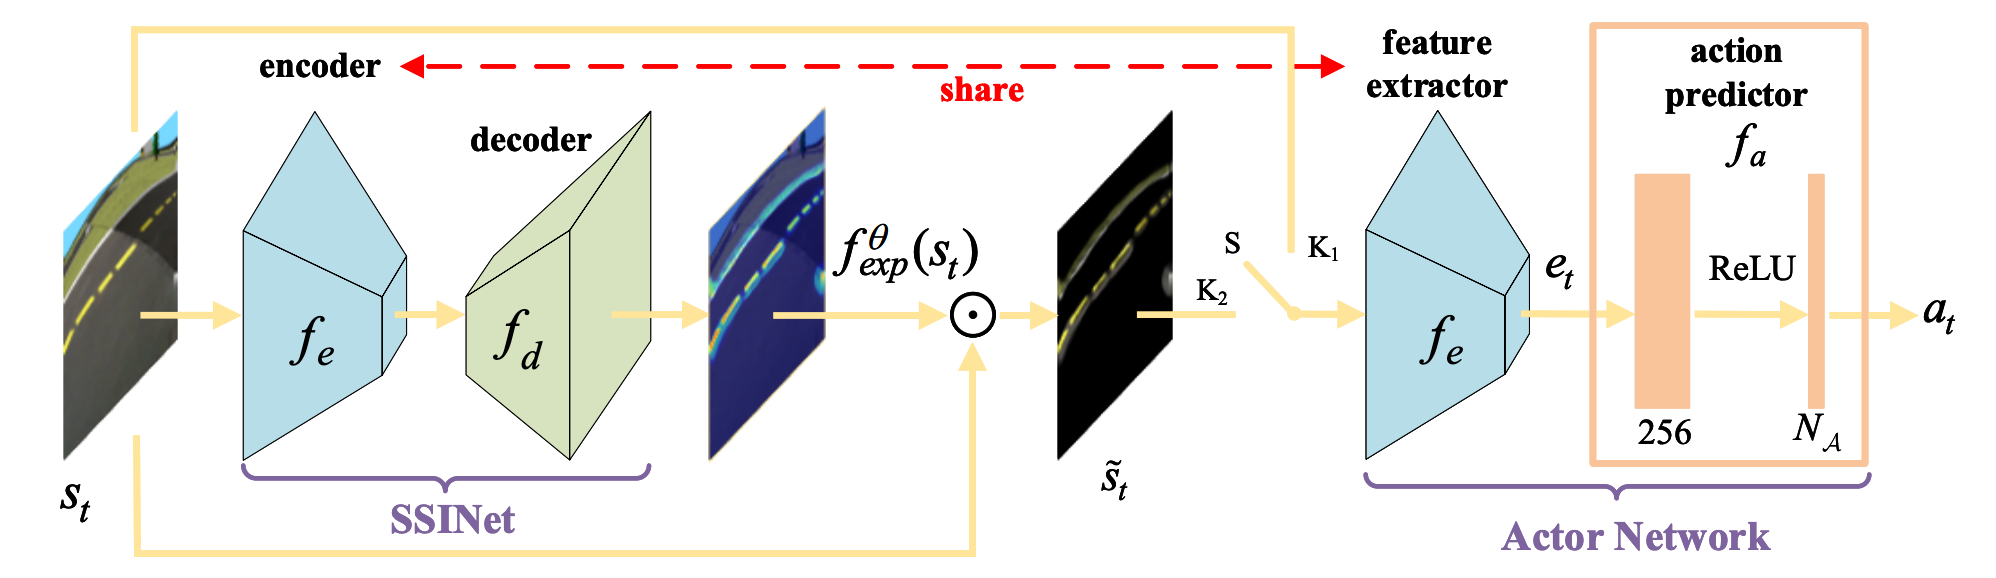 Self-Supervised Discovering of Interpretable Features for Reinforcement LearningIEEE Transactions on Pattern Analysis and Machine Intelligence, 2020


